Description
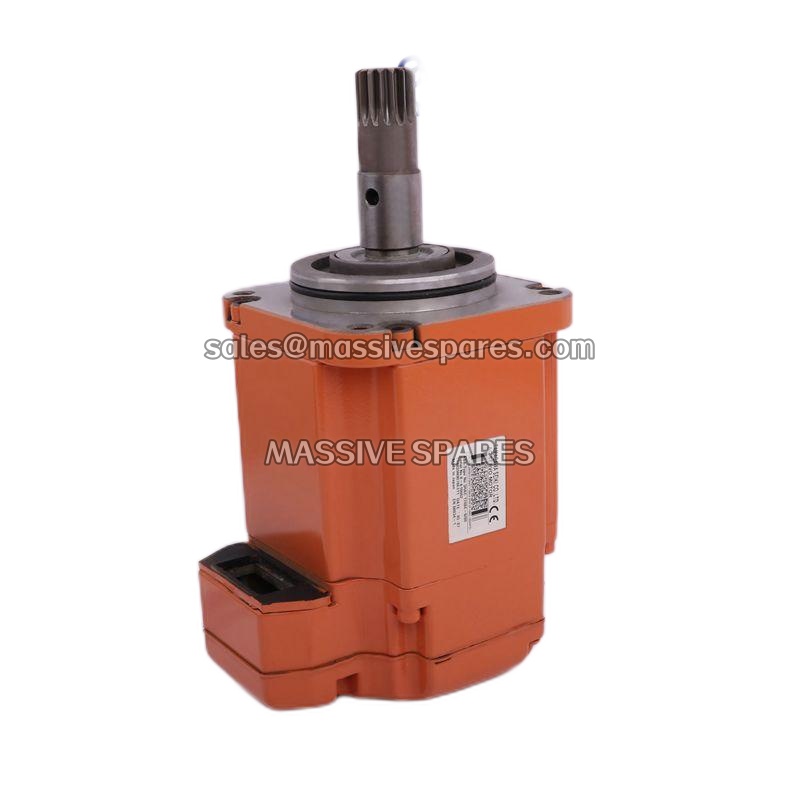
The ABB 3HAC10602-2 is a robotic joint servo motor manufactured by ABB Robotics (ABB Robotica, Sweden/Switzerland) and serves as the wrist motor unit for Axis 4 (wrist roll / orientation) and Axis 6 (tool-flange roll / end-effector rotation) of the ABB IRB 2400 family — covering the IRB 2400, 2400L, and 2400T variants across the 7 kg, 10 kg, and 16 kg payload classes . It is a three-phase permanent-magnet synchronous motor (PMSM) in ABB’s small wrist-motor frame, integrating the stator and rotor, a spring-applied parking brake, position feedback (resolver on the -2 suffix; some BOM revisions carry a 2048 PPR incremental encoder), a winding thermal protector, and a keyed circular wrist connector into a single cast-aluminum, fanless, IP54 assembly .
In plain terms, 3HAC10602-2 is what makes the robot’s wrist feel “smooth.” Axes 4 and 6 do the most cycles in welding and handling — every gun orientation, every part re-position, every arc on/off toggles one or both. The motor bolts to the input flange of the axis-4 or axis-6 gearbox inside the wrist housing, its shaft driving the sun gear, and it is fed from the cabinet drive bus via the hollow-arm wrist harness . When it ages, the robot does not fail dramatically. It develops micro-judder, loses repeatability by fractions of a millimeter, and starts reporting encoder-deviation alarms — the kind of fault that quality control finds before maintenance does.
Application Scenarios
A Tier-1 automotive weld shop in Germany runs 22 IRB 2400 robots on a two-shift spot-welding line. After nine years, three cells develop the classic symptom: a faint wrist judder during gun orientation, accumulating to roughly ±1.5 mm of weld-point drift that line QC keeps rejecting . The integrator’s first instinct is a controller retune. Current-signature analysis points elsewhere — to the wrist. The ABB 3HAC10602-2 on A4/A6 has bearing play, and its feedback pulses drift under thermal load.
Swapping in a fresh, pre-aligned 3HAC10602-2 restores wrist repeatability to better than 0.05 mm within the same shift — no robot re-mastering, no S4C+ or IRC5 parameter change, just unbolt the old wrist motor cassette, bolt the new one, run a quick “Calibrate Axis 4, 6,” and the cell is welding again . For a line where one robot down puts 120 bodies per hour at risk, a half-day repair pays for itself before lunch. And because A4 and A6 share the same part number, the plant carries one spare for both wrist axes across all 22 cells — eight wrist-motor positions on four robots, all covered by the same box in the MRO cage.
Parameter
| Main Parameters | Value / Description |
|---|---|
| Product Model | 3HAC10602-2 (ABB Robotics order number) |
| Manufacturer | ABB Robotics (ABB Robotica), Sweden / Switzerland |
| Product Category | Robotic joint servo motor unit (wrist assembly, dual-axis common PN) |
| Robot Compatibility | IRB 2400 / IRB 2400L / IRB 2400T (full family, 7/10/16 kg payload classes) |
| Supported Axes | Axis 4 (wrist roll / orientation, ±400° working, unlimited with option) and Axis 6 (tool-flange roll, ±800° working, unlimited with option) |
| Motor Type | 3-phase permanent-magnet synchronous motor (PMSM), small wrist-motor frame (M16/M23 class) |
| Rated Voltage | 230 V AC line-to-line equivalent at the U/V/W terminals (derived from the robot DC link; supply to cabinet 200–600 V AC 50/60 Hz) |
| Continuous Torque (motor shaft, before reduction) | Axis 4: 12 N·m ; Axis 6: 8 N·m (typical) |
| Maximum Speed | 3000 rpm |
| Position Feedback | Resolver (ruggedized, vibration- and dust-resistant); -2 suffix. Note: some BOM revisions specify an incremental optical encoder, 2048 PPR — confirm against the removed unit |
| Brake | Integrated spring-applied parking brake, power-off engaged, 24 V DC release coil |
| Thermal Protection | Winding thermal protector (KV class), wired to the drive’s motor-temperature input; trips “Motor Overtemp” above roughly 130 °C winding temperature |
| Connector | ABB proprietary keyed circular wrist connector (12-pin / 19-pin class), carrying U/V/W + brake + resolver/encoder + temp sensor |
| Mounting | Bolts to the axis-4 or axis-6 gearbox input flange inside the wrist housing; shaft splined/keyed into the gearbox input sun gear |
| Cooling | Natural convection (flange conduction + housing radiation), fanless |
| Protection Class | IP54 (dust and splash resistant; Foundry Plus / IP67 washdown is a separate robot option, not this motor) |
| Operating Temperature | 0 °C to +50 °C (wrist environment; cabinet drive range is wider) |
| Storage Temperature | –20 °C to +70 °C |
| Humidity | 5 % to 95 % RH, non-condensing |
| Winding Treatment | Vacuum-impregnated (varnish-dipped) stator windings for moisture and flux-fume resistance |
| Bearings / Lubrication | Deep-groove ball bearings, lifetime grease |
| Physical Dimensions | Approx. 250 × 150 × 100 mm envelope (including connector boss) |
| Weight | Approx. 4.2 kg (complete assembly: motor, brake, feedback, connector) |
| Supported Controllers | S4C+ (M2000-era IRB 2400) and IRC5 (later IRB 2400) |
| Matching Drive | ABB DSQC-series robot drive unit / IRC5 drive module (cabinet-internal; not part of this item) |
| Compliance | CE; produced to ISO 9001 ABB Robotics standards |
| Lifecycle Status | Last Call / end of life — ABB lead time cited as 16–24 weeks; new-old-stock window expected to close within 2–3 years |