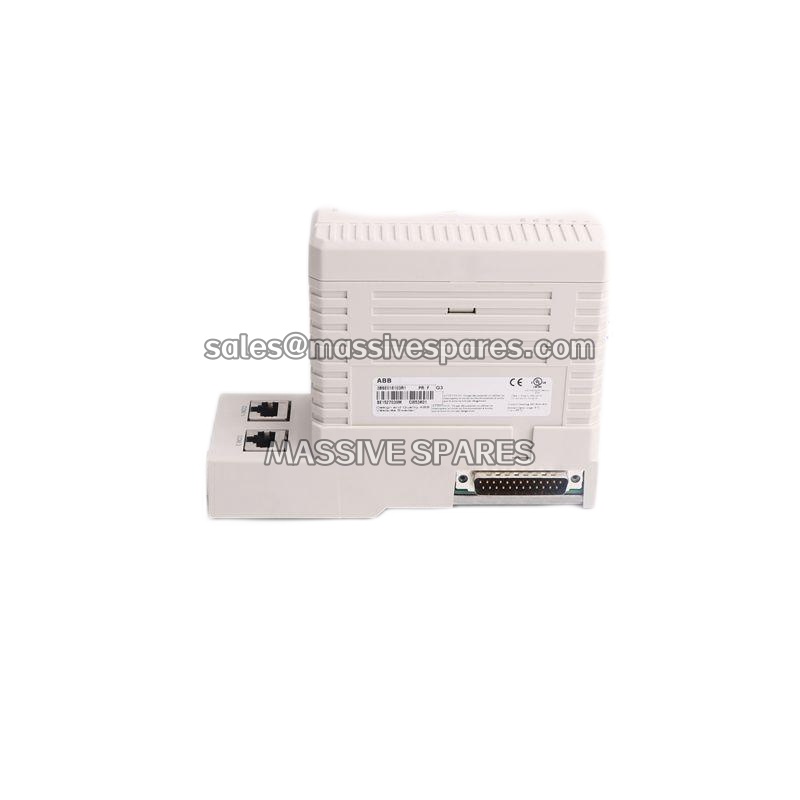
Application Scenarios
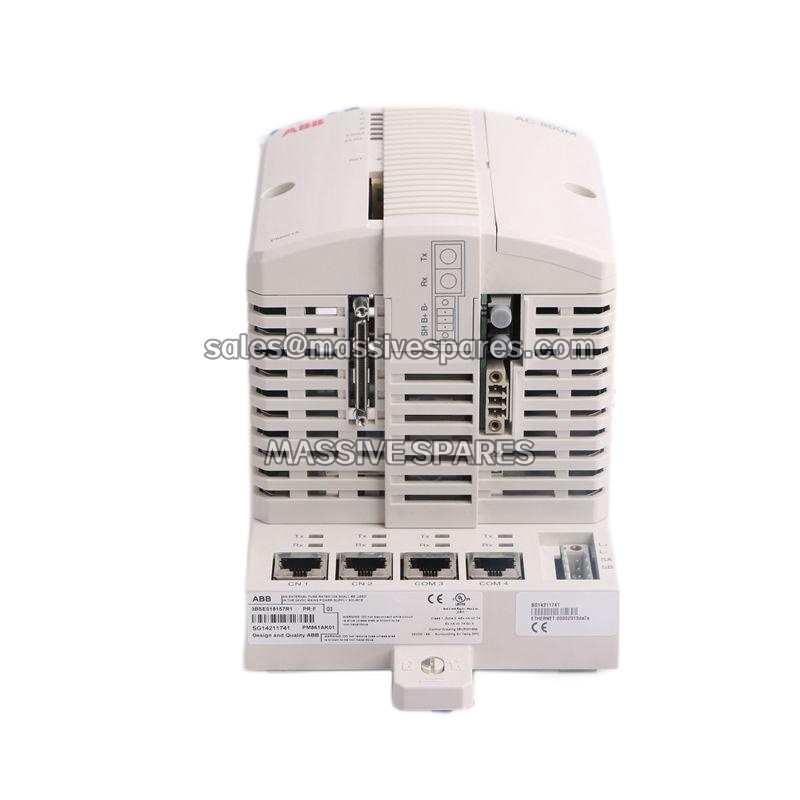
In an automotive-tier spot-welding cell running four IRB 2600-20 robots, the axis-3 waist joint was originally assigned a 14 A drive despite drawing only ~5.8 A continuous under normal cycling. During a mid-life spares audit, the integrator swapped that axis to a 3HAC14549-3/07A unit. The 7 A continuous envelope with 21 A peak headroom covers the axis-3 steady-state load with acceleration transients intact, and the smaller footprint freed one drive-slot position in the IRC5 cabinet that later hosted an external-axis drive for a turntable positioner. Two years after the retrofit, the cell reported zero drive-layer thermal trips, and the spare-store inventory simplified from three drive ratings down to two (07A and 14A).
Parameters
| Main Parameters | Value/Description |
|---|---|
| Product Model | 3HAC14549-3/07A |
| Manufacturer | ABB (Robotics / Motion) |
| Product Category | Servo Drive Unit (IRC5 cabinet-internal) |
| Compatible System | ABB IRC5 Single/Standard Cabinet |
| Supply Voltage | AC 200–240 V, 50/60 Hz |
| Output Current | 7 A continuous / 21 A peak (3 s) |
| Control Modes | Torque / Speed / Position (vector control) |
| Feedback Interface | Incremental and absolute encoder support |
| Communication Uplink | EtherCAT, Profibus DP (to IRC5 master) |
| Dynamic Response | < 1 ms torque step; ~2 kHz velocity-loop bandwidth |
| Protection | Over-current, over-voltage, STO-ready |
| Mounting | IRC5 drive-layer tray / DIN rail |
| Dimensions / Weight | ~180 × 120 × 250 mm / ~2.5 kg |
| Operating Temperature | 0 °C to +40/+50 °C (cabinet-forced-air) |
Technical Principles and Innovative Values
- Right-Sized Drive Rating for 20 kg-Class Manipulators: ABB’s IRC5 drive layer scales in discrete current brackets (03A / 07A / 14A / 28A). The 3HAC14549-3/07A lands precisely on the steady-state and transient envelope of IRB 2600 axis-3/axis-6 and full-axis IRB 1600/1660 builds. Oversizing to a 14 A unit wastes cabinet slot budget and backplane resources; undersizing to a 03A unit clips acceleration transients. The 07A represents the correct engineering match for mid-payload robot axes.
- Sub-Millisecond Torque Response with 2 kHz Bandwidth: The 3HAC14549-3/07A executes ABB’s vector-control algorithms with a velocity-loop bandwidth around 2 kHz and torque-step response under 1 ms. In a spot-weld cycle where the robot decelerates from 2 m/s to zero in ~120 ms while the weld gun is still closing, this response speed prevents axis droop and maintains tip-position accuracy through the dynamic transient.
- Cabinet-Internal Form Factor with Drive-Layer Integration: The unit mounts directly into the IRC5 drive tray alongside other 07A/14A modules, sharing the cabinet’s backplane power and communication infrastructure. This plug-in architecture allows axis-to-drive mapping to be changed through the IRC5 configuration, not through external wiring or separate drive panels.